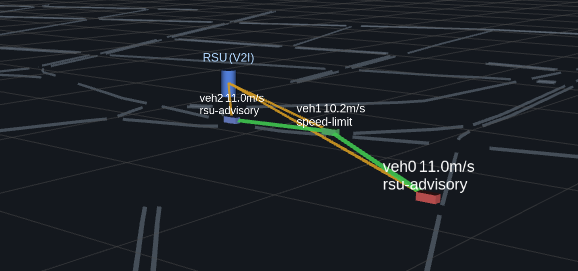
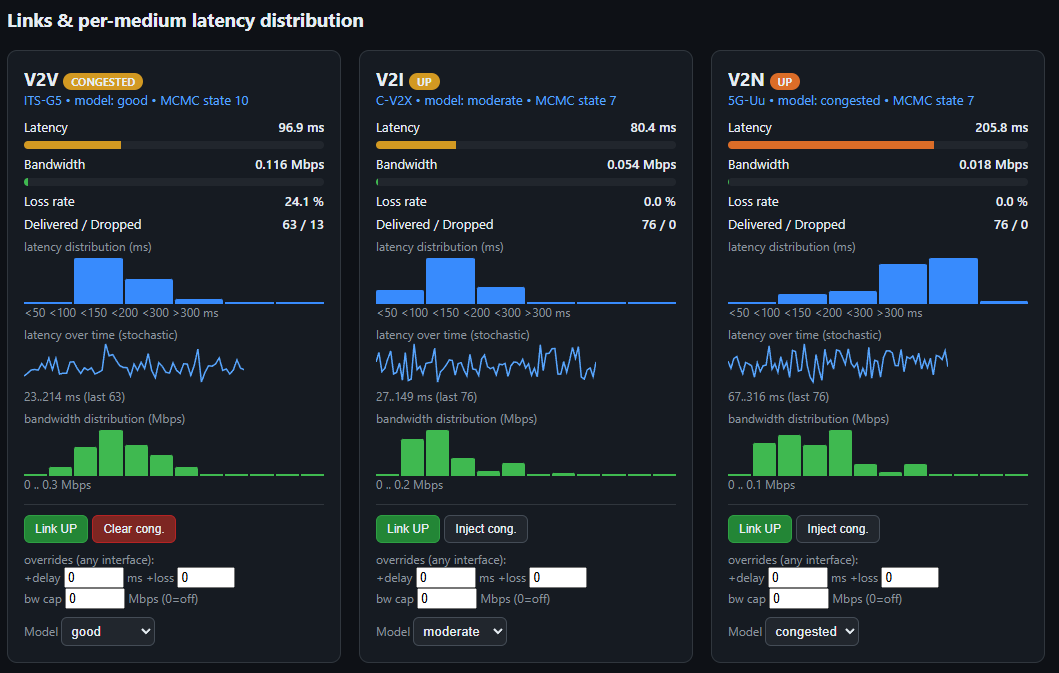
The demonstrator investigates three main use cases: (1) Emergency Braking, where vehicles exchange hazard information to reduce crashes and improve reaction times; (2) Traffic Jam Detection and Mitigation, where shared traffic information is used to minimize congestion, queue lengths, and travel times; and (3) Vehicle/Truck Platooning, where coordinated driving improves road throughput, fuel efficiency, and traffic flow. Each use case is assessed using a SUMO + ROS 2 testbed and will compare four communication configurations (no communication, V2N-only, V2V-only, and bonded multi-link communication) under varying packet loss, latency, bandwidth, and traffic conditions.
See how the demonstrator works in the video below:
Blog signed by: AVL team